
The human immune system is a highly sophisticated system of biological structures that defends the human body against harmful antigens. In this paper, the concept of biological immune system, idiotypic network theory and clonal selection theory are applied in multi-robot cooperation. Idiotypic network theory governs the stimulation and suppression of an antibody in response to an antigen. Clonal selection theory represents how immune cells mutate and proliferate into memory cells. The methodology presented in this paper is autonomous and de-centralized. In the proposed system, the robots work effectively to complete a task either alone or co-operatively. Specifically, the coordination and communication among various robots are established based on the concept of immune system, idiotypic network theory and clonal selection theory. The developed methodology is successfully implemented through simulation. The experiments show that the simulated robots completed all tasks effectively.
Research Article · Volume 39, Issue 1, 12 February 2021 · Open Access
Cooperative Multi-Robot Framework Using Artificial Immune System and Fuzzy Logic
· · ·
Affiliations & Notes ⌄
- 1Department of Electronics, University of Peshawar, Pakistan
- 2Department of Mechatronics Engineering, University of Engineering and Technology Peshawar, Pakistan. *Correspondence: Muhammad Tahir Khan, Department of Mechatronics Engineering, University of Engineering and Technology Peshawar, Pakistan
- 3Email: tahir@uetpeshawar.edu.pk
Article Info ⌄
- Journal:
- Journal of Engineering and Applied Sciences
- Published:
- 12 February 2021
Abstract
The full text of this article is available as a PDF — use Download PDF above.
Figures
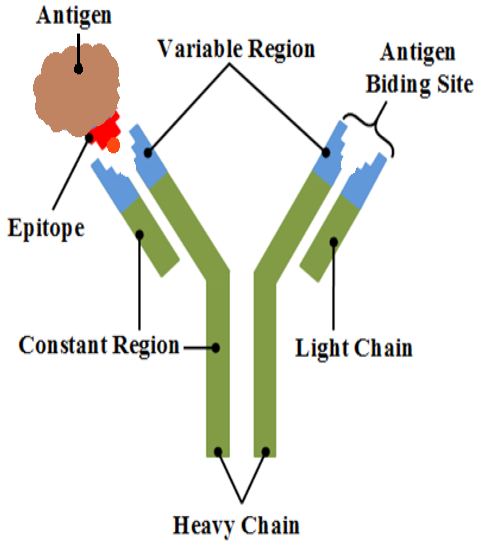
Antibody’s structure.
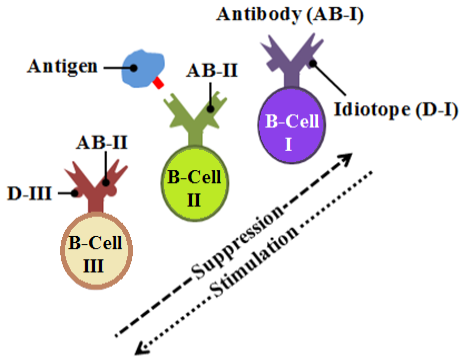
Idiotypic network theory.
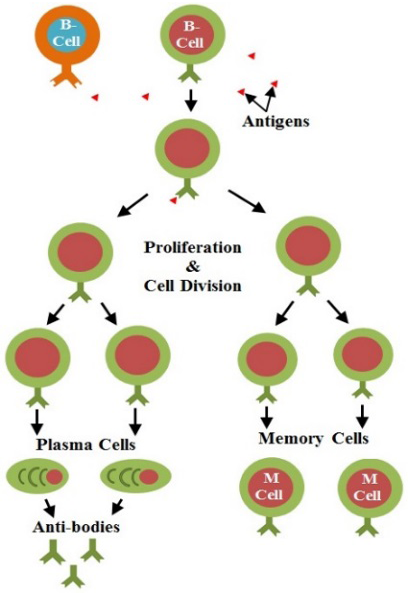
Clonal selection theory.
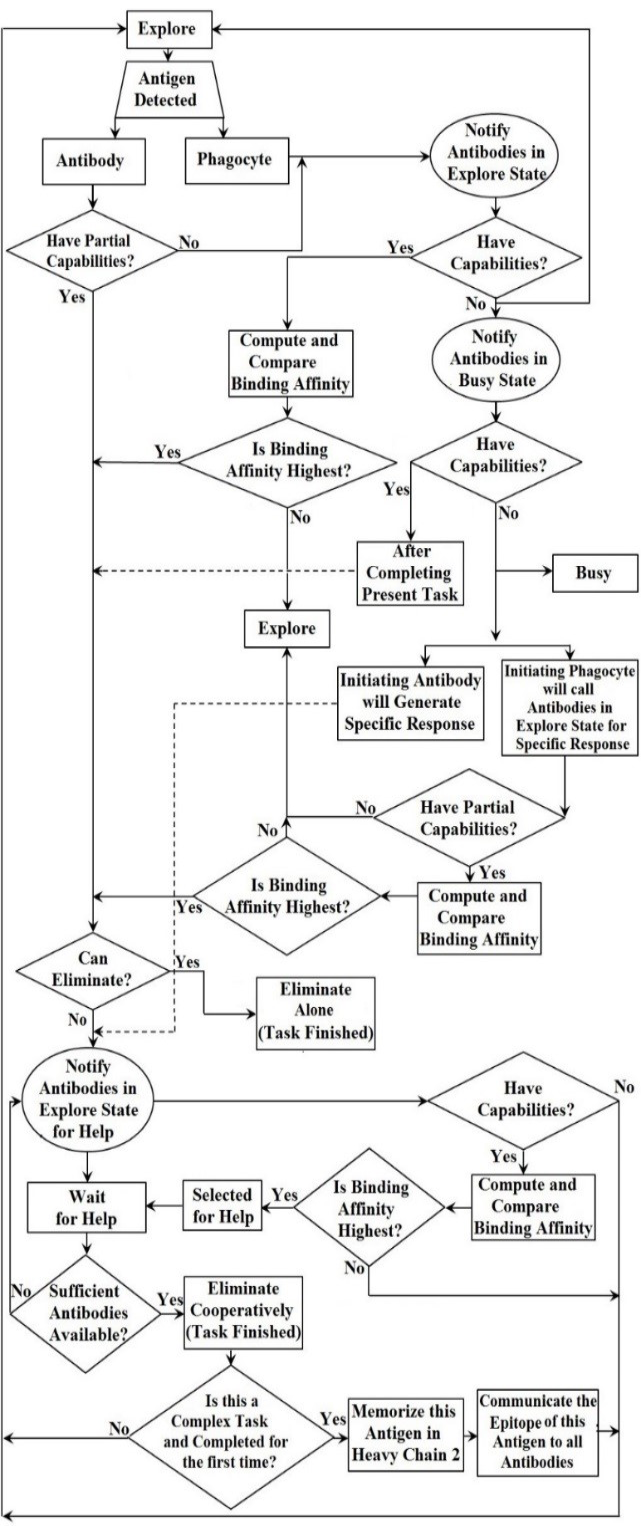
Control framework for MRC.
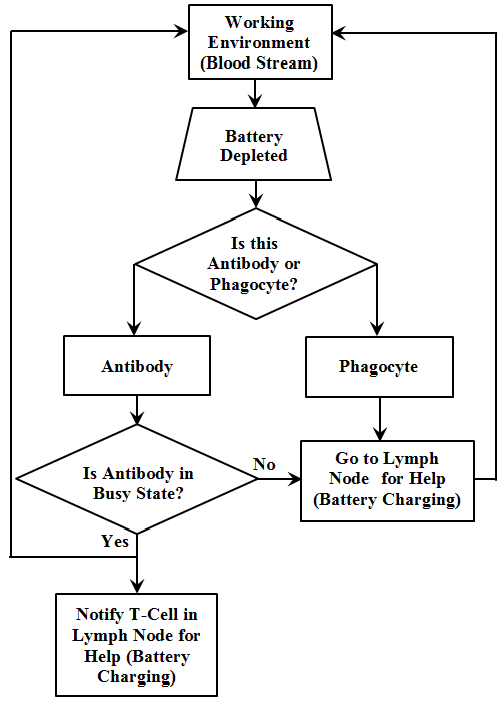
Flowchart for battery charging of a robot.
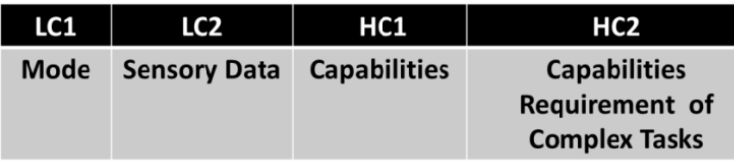
Antibody’s (B-robot) light and heavy chains.
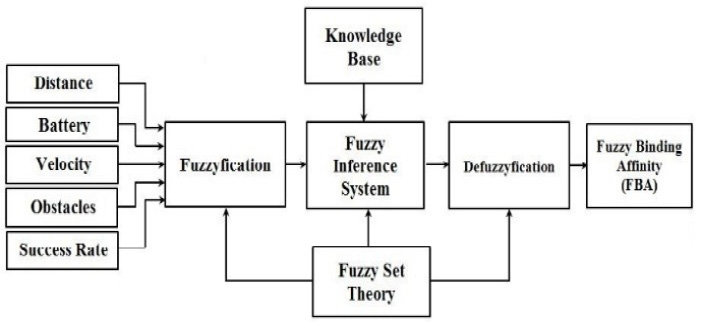
Block diagram of the proposed algorithm for fuzzy binding affinity.
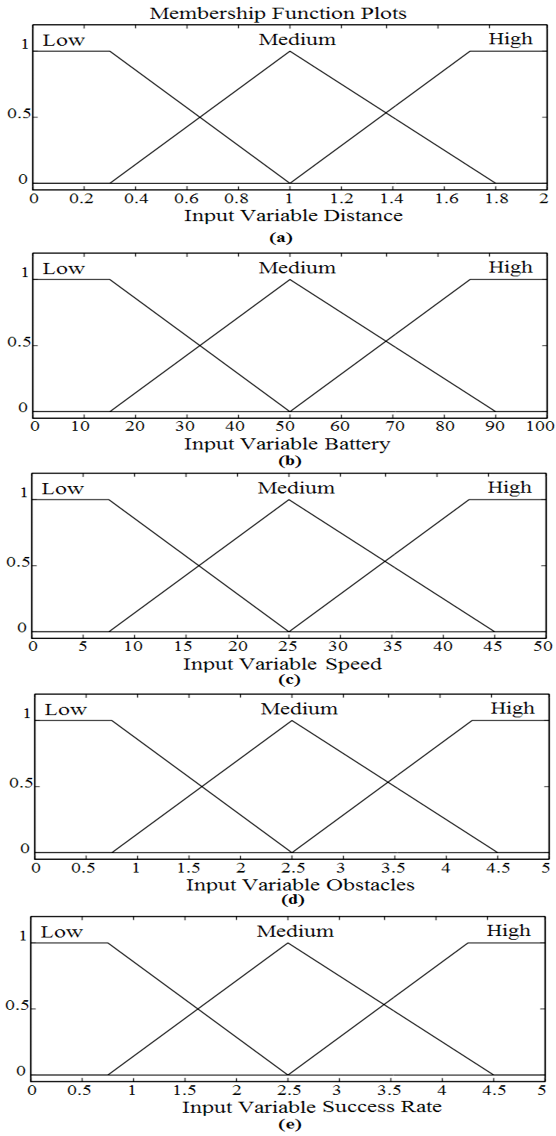
Input membership functions:(a) Distance, (b) Battery, (c) Speed, (d) Obstacles, (e) Success rate.
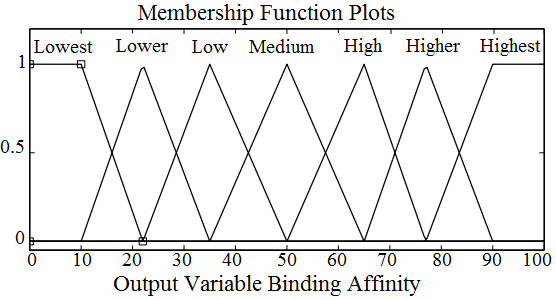
Output Binding Affinity membership function.
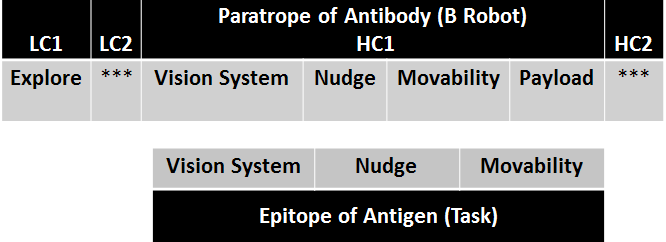
Comparison of the paratrope of antibody (B-robot) with epitope of task.
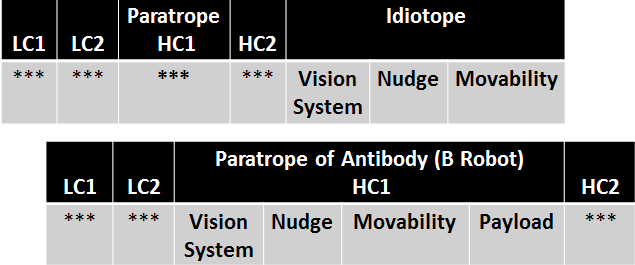
Matching of the antibody (B-robot) paratrope and idiotope.
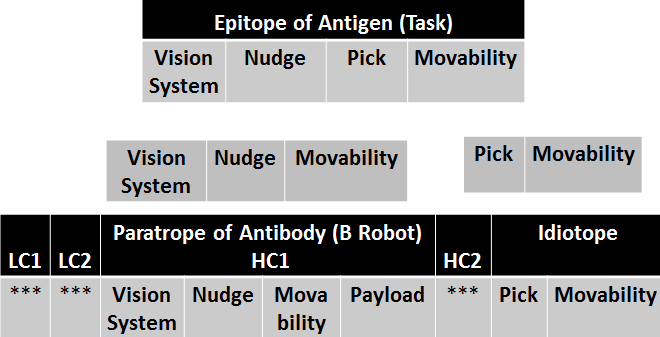
Response of the antibody to a complex antigen (task).
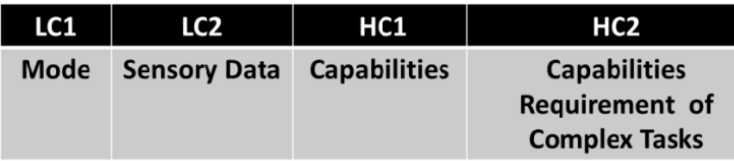
Heavy chain HC2 showing capabilities of the task accomplished through a specific response.
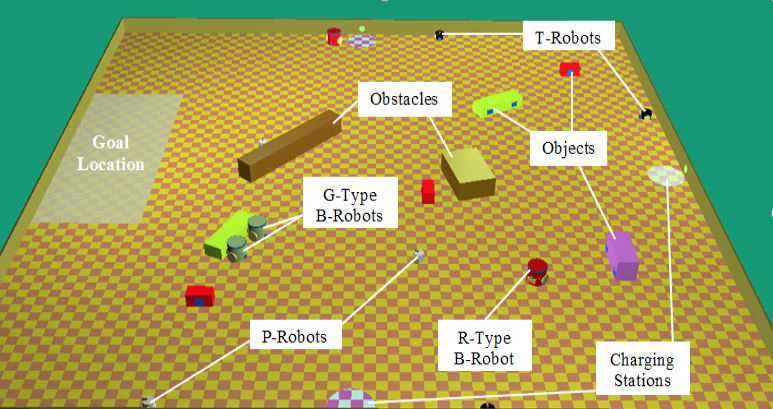
Simulation platform.
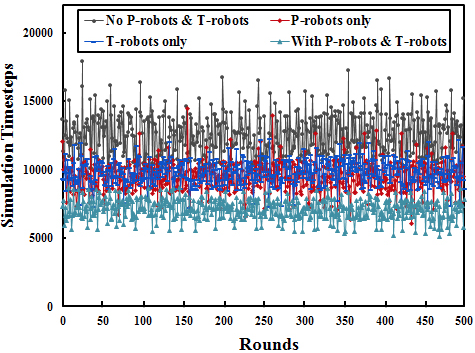
Time (stpes) spent in each run to complete the tasks.
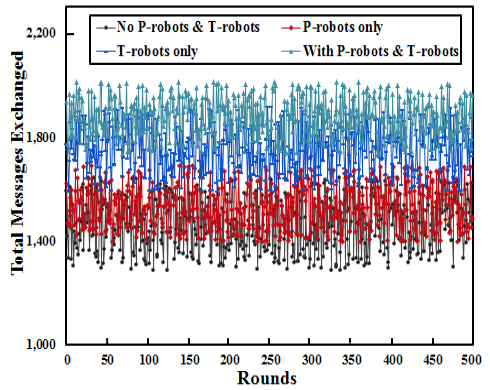
Total messages exchanged during task accomplishment in each run.
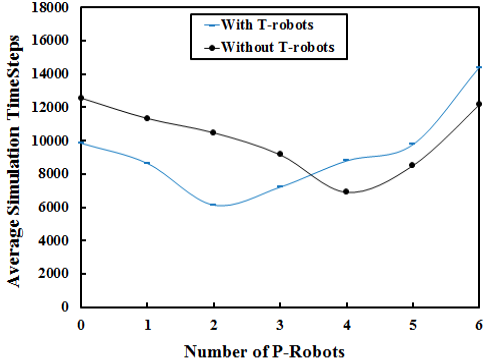
Average time (steps) taken to complete the tasks as a function P-robots.
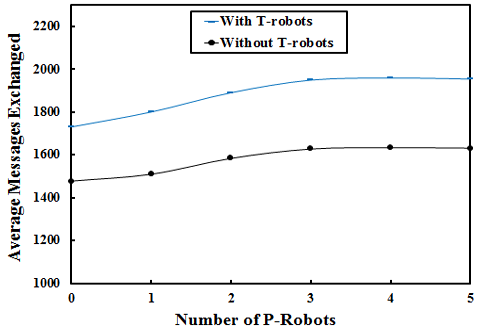
Average messages exchanged during tasks completion as a function of P-robots.
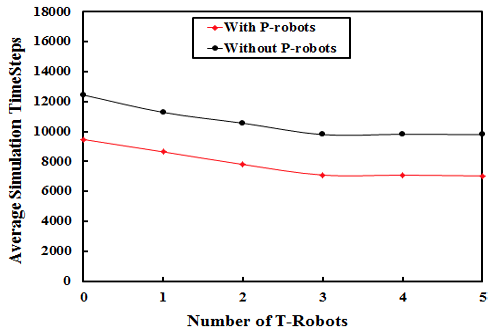
Average time (steps) taken to complete the tasks as a function T-robots.
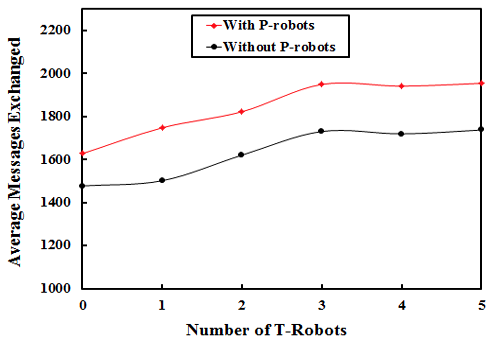
Average messages exchanged during tasks completion as a function of T-robots.
Services
Article usage statistics
Loading…